About me
I am an embodied AI and robotics researcher. I’m a PhD student in Electrical, Computer, and Systems Engineering at Rensselaer Polytechnic Institute, advised by Dr. Santiago Paternain, and a part-time PhD Research Intern with the Robotics and Autonomy team at GE Aerospace Research, where I was a full-time PhD Research Intern in Summer 2026.
My research sits where AI meets robotics. I study efficient, scalable decision-making and planning for single and multi-robot systems, drawing on generative models, reinforcement learning, optimal control, and dynamic games. Before RPI, I earned my B.S. and M.S. in Aerospace Engineering at the University of Illinois Urbana-Champaign, advised by Dr. Negar Mehr, now a professor at UC Berkeley.
Off the clock
I moved to the U.S. at 16 and finished high school in Columbia, South Carolina. These days, when I’m not tuning cost functions, you’ll find me at the piano, at the gym, or deep in a psychology book, somewhere between Freud and Carl Jung. (No, I won’t analyze your dreams. Probably.)
I also sing, mostly Jay Chou (周杰伦), the Bruno Mars of Asia. I’ve been a devoted fan since I saw him live in 2013, at the seasoned age of 13.
And I’m a credit card points guru. Points and miles are just another optimization problem to me, and the optimal solution is free flights and hotel nights between the U.S. and Asia. I vlog some of those trips on my YouTube channel, so you can watch the solution converge in real time.
Research interests
-
Generative AI for whole-body control and locomotion
Using generative models such as diffusion models to produce coordinated whole-body control and locomotion for robots.
-
Trajectory optimization in safety-critical scenarios
Fast, constraint-aware trajectory optimization that keeps single robots and teams of robots safe, drawing on diffusion-based solvers, optimal control, and dynamic games.
News
Started as an Embodied AI and Robotics PhD Fellow Intern at GE Aerospace Research, and stayed on this fall with the Robotics and Autonomy team.
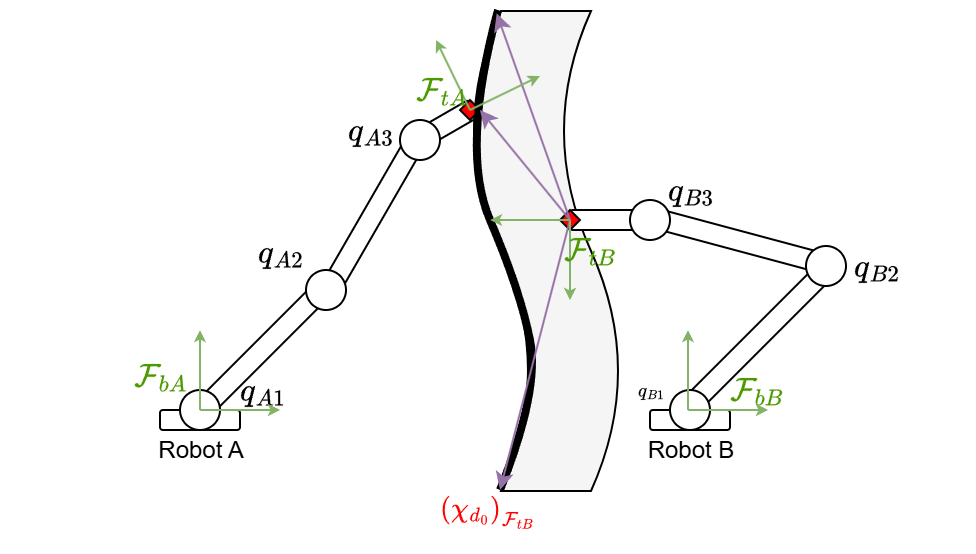
Our paper "Diffusion-Based Optimization for Accelerated Convergence of Redundant Dual-Arm Minimum Time Problems" was accepted to the 2026 IEEE Conference on Decision and Control (CDC).
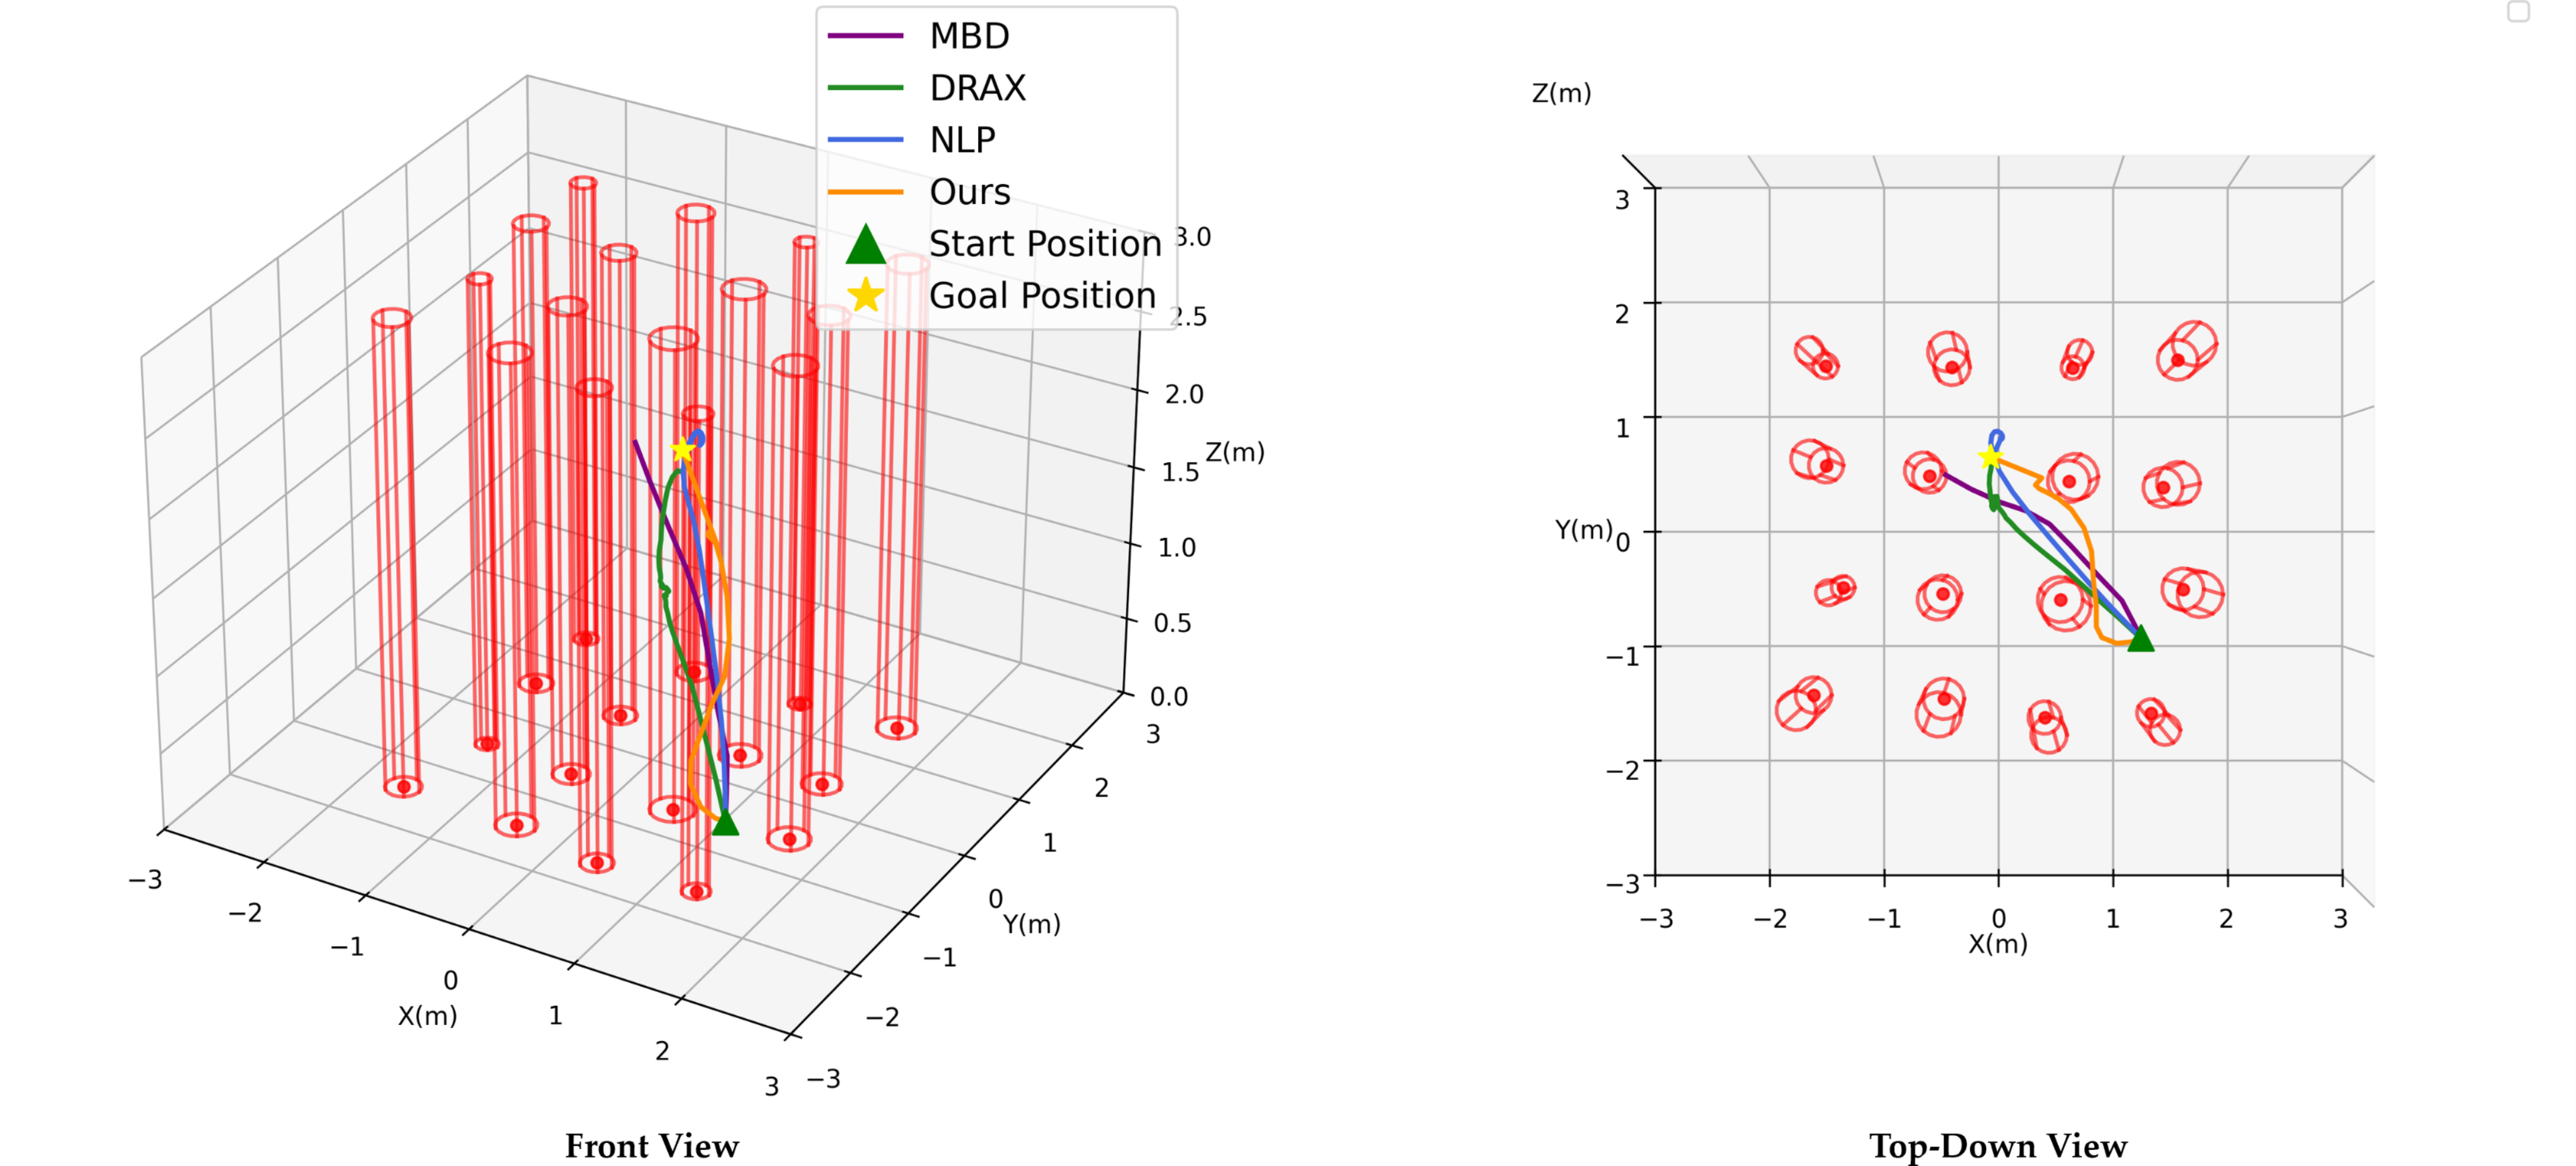
Our paper "PAD-TRO: Projection-Augmented Diffusion for Direct Trajectory Optimization" was accepted to the 2026 American Control Conference.
Started as a Control Systems Intern at DEKA Research & Development.
Our preprint "Learning Closed-Loop Parametric Nash Equilibria of Multi-Agent Collaborative Field Coverage" is on arXiv.
Finished my M.S. in Aerospace Engineering at UIUC. My thesis, "Improved pose estimation accuracy of monocular deep visual odometry against dynamic entities via adversarial training," is publicly available.
Became a U.S. permanent resident.
Our paper "Distributed Potential ILQR: Scalable Game-Theoretic Trajectory Planning for Multi-Agent Interactions" was accepted to ICRA 2023.
Publications
-
CDC 2026
Diffusion-Based Optimization for Accelerated Convergence of Redundant Dual-Arm Minimum Time Problems
2026 IEEE Conference on Decision and Control (accepted)
-
ACC 2026
PAD-TRO: Projection-Augmented Diffusion for Direct Trajectory Optimization
2026 American Control Conference
-
ICRA 2023
Distributed Potential ILQR: Scalable Game-Theoretic Trajectory Planning for Multi-Agent Interactions
IEEE International Conference on Robotics and Automation (ICRA), 2023